Precision You Can Trust
NABL-Accredited Calibration | Available on Request
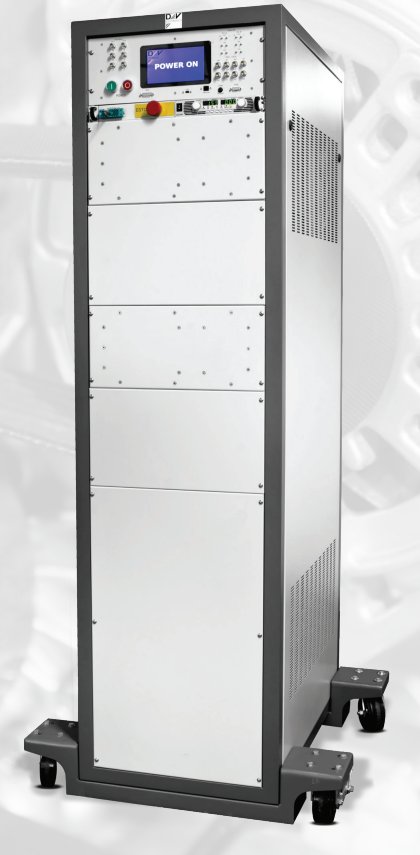
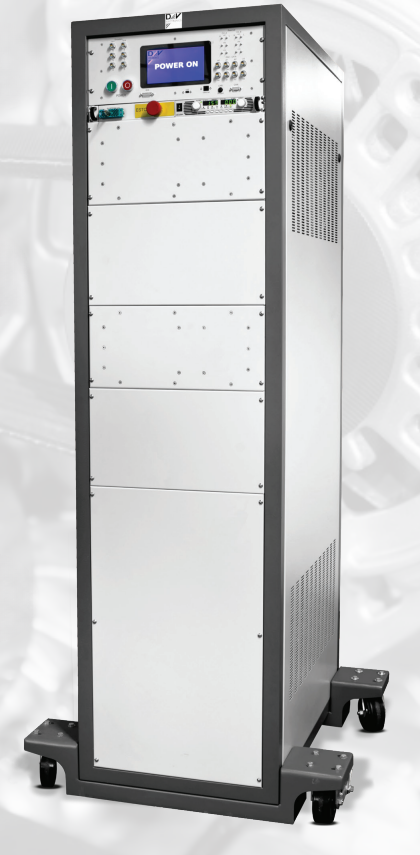
A lab-safe, standalone electronic dynamometer alternative that emulates electric motors for inverter design validation, endurance testing, and high-volume production. Supports 48 V, 350 V and 800 V vehicle platforms with integrated battery emulation and scalable high-power architecture..
The Electric Motor Emulator replicates true 4-quadrant motor behavior, including torque generation, BEMF, impedance, and temperature-dependent reactions. It allows accurate inverter testing even before a physical motor prototype exists, reducing project timelines and risks.
Engineers can test switching strategies such as SVM, sine-triangle or DPWM, while monitoring transient events without the mechanical hazards of a spinning motor. The emulator is designed to handle demanding EV inverter tests, including rapid acceleration, sudden load changes and long overload cycles.
Multiple configurations support upgrading from single-motor to dual-motor testing and parallel stacking for high current and multi-phase platforms. Voltage levels are selectable to match different EV architectures (48 / 350 / 800 V), making it ideal for current and next-gen e-powertrain development.
A PC-based GUI and automation-friendly CAN interface allow complete control of both the emulator and the unit under test. When combined with real-time simulation, the platform delivers a full HIL/P-HIL setup for advanced inverter development.
Internal HV & LV battery emulators for complete inverter testing without real batteries
Configurable motor models with drive-cycle simulation and P-HIL compatibility
Circulates AC/DC power between inverter and emulator, reducing facility power to only ~25% of system rating
Flexible 3-phase or 6-phase operation, scalable up to 1.1 MW by paralleling multiple units
Safe validation of extreme conditions such as overspeed, burst and locked rotor
No moving parts, minimal maintenance, and compact footprint with caster mobility
70+ DAC outputs provide motor parameters that real machines cannot easily expose
| Category | Specification |
|---|---|
| Motor Emulation | Synchronous PM or Induction, 3-phase or 6-phase |
| Number of Motors | 1 or 2 per system depending on model |
| Continuous Power | 150 kW to 275 kW per emulator (up to 550 kW combined) |
| AC Current | 350 Arms continuous, 550 Arms peak (scalable to 1400 Arms) |
| Voltage Capability | 0–365 VAC L-L or 0–700 VAC L-L |
| Frequency Range | DC to 1500 Hz |
| Torque & Rotation | Forward and reverse torque control |
| Motor Poles | 2 to 40 |
| Position Sensor Emulation | Resolver (2–24 lobes) / Encoder (up to 80 pulses per revolution) |
| Phase Resistance | 0–1000 mΩ |
| Phase Inductance | 30 µH – 2000 µH |
| LV Battery Emulation | 8–30 VDC, up to 25 A |
| Interface | PC GUI, CAN automation, P-HIL fiber interface |
| Cooling | Water-based cooling system |
| Footprint & Size | Standard cabinet ~23" x 39", height ~75-86" |
| Weight | Approx. 820–1800 kg depending on configuration |
| Model | Motors | Voltage Platform | Max Continuous Power |
|---|---|---|---|
| 150500-1 | 1 | 500 V | 150 kW |
| 250500-2 | 2 | 500 V | 250 kW combined |
| 275960-1 | 1 | 960 V | 275 kW |
| 550960-2 | 2 | 960 V | 550 kW combined |